SCAPE 3D Industrial Scanners
Four distinct product families for part recognition, positioning and quality control in robotic cells — from compact wrist-mounted models to fixed systems built for wide-area scanning.
SCAPE Grid Scanner Recognition™
Works on a patented, image-based recognition method: it combines 2D image features with 3D point cloud data, reliably recognizing even highly reflective (shiny/mirror-like) parts from a single frame. The point cloud is generated by capturing an LED-projected grid with the camera. It mounts directly to the robot wrist; an adjustable field of view across different working distances gives versatile use without being limited by bin count or position.
SCAPE Grid Scanner Recognition™ — Tool Unit Compact
| Size class | Compact housing, direct wrist mount |
| Near Range — Nominal distance | 340 mm |
| Near Range — Working range | 280–480 mm |
| Near Range — Field of view (FOV) | 205 × 205 mm |
| Near Range — Lateral resolution (XY) | 1.05 mm |
| Near Range — Depth uncertainty (RMS) | 0.25 mm |
| Far Range — Nominal distance | 445 mm |
| Far Range — Working range | 325–565 mm |
| Far Range — Field of view (FOV) | 271 × 271 mm |
| Far Range — Lateral resolution (XY) | 1.37 mm |
| Far Range — Depth uncertainty (RMS) | 0.44 mm |
| Extended Range | To be determined (will be added once manufacturer data is updated) |
SCAPE Grid Scanner Recognition™ — Tool Unit Standard / Large
| Size class | Standard/Large housing, direct wrist mount |
| Near Range — Nominal distance | 460 mm |
| Near Range — Working range | 400–630 mm |
| Near Range — Field of view (FOV) | 275 × 275 mm |
| Near Range — Lateral resolution (XY) | 1.42 mm |
| Near Range — Depth uncertainty (RMS) | 0.30 mm |
| Far Range — Nominal distance | 600 mm |
| Far Range — Working range | 450–750 mm |
| Far Range — Field of view (FOV) | 395 × 395 mm |
| Far Range — Lateral resolution (XY) | 1.85 mm |
| Far Range — Depth uncertainty (RMS) | 0.50 mm |
| Extended Range — Nominal distance | 730 mm |
| Extended Range — Working range | 480–860 mm |
| Extended Range — Field of view (FOV) | 434 × 434 mm |
| Extended Range — Lateral resolution (XY) | 2.25 mm |
| Extended Range — Depth uncertainty (RMS) | 0.80 mm |
Preferred wherever wrist-mounted use offers an advantage: close-range inspection of large parts, object-location detection across different zones within the robot's reach, robot navigation, and vision-guided robot control.
SCAPE Mini Industrial 3D Scanners
Part of SCAPE's hand-eye 3D sensor family, the Mini series uses a powerful laser source with high resistance to ambient light. Its rugged, compact and lightweight design allows direct wrist mounting, making it suitable for high-precision tasks such as guidance, grasping and weld-seam detection. A wide field of view within the robot's reach gives integrated systems high flexibility without being limited by bin count or position.
SCAPE Mini Pro-700
| Dimensions (W×D×H) | 120 × 100 × 55 mm |
| Weight | 0.78 kg |
| Baseline | 80 mm |
| Working range | 400–700 mm |
| Near FOV | 400 × 350 mm @ 400 mm |
| Far FOV | 700 × 600 mm @ 700 mm |
| Point spacing (point cloud) | 0.47 mm @ 500 mm |
| Exposure mode (depth camera) | Global shutter |
| Accuracy — Z | < %0.1 |
| Accuracy — X/Y | < %0.5 |
| Resolution | 1280 × 1024 piksel |
| Scan time (typical) | 0.7–1.1 sn |
| Data output | Point cloud — wrl, obj, pcd, ply |
| API | C++, C# |
| Operating system | Windows 10/11 |
| Hardware interface | Hirose 8pin, Ethernet |
| Operating temperature | 0–40 °C |
| Storage temperature | −20–70 °C |
| Relative humidity | %20–80 RH |
| Protection class | IP65 |
| Power input | PoE |
| Power consumption | 16 W |
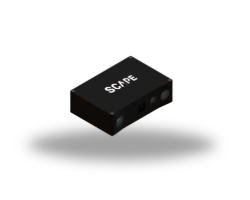
SCAPE Mini Pro C-700
| Dimensions (W×D×H) | 165 × 115 × 49 mm |
| Weight | 1.03 kg |
| Baseline | 125 mm |
| Working range | 400–700 mm |
| Near FOV | 400 × 350 mm @ 400 mm |
| Far FOV | 700 × 620 mm @ 700 mm |
| Color camera field of view | H: 66° / V: 53.6° |
| Point spacing (point cloud) | 0.47 mm @ 500 mm |
| Exposure mode | Depth: Global shutter · Color: Rolling shutter |
| Accuracy — Z / X-Y | < %0.1 / < %0.5 |
| Resolution — Depth | 1280 × 1024 piksel |
| Resolution — Color camera | 3600 × 2800 piksel |
| Scan time (typical) | 0.7–1.1 sn |
| RGB-D alignment | Yes |
| Data output | Depth, point cloud (wrl/obj/pcd/ply), color camera image |
| API | C++, C#, Python, Halcon |
| Operating system | Windows 10/11, Ubuntu 16.04/18.04/20.04 |
| Hardware interface | PoE IEEE 802.3at · Ethernet M12 X-CODE, GigE, IEEE1588 |
| Operating / Storage temperature | 0–40 °C / −20–70 °C |
| Relative humidity | %20–80 RH |
| Protection class | IP65 |
| Power input / consumption | PoE / 16 W |
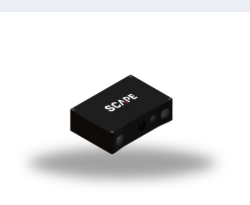
SCAPE Mini Pro C-1000
| Dimensions (W×D×H) | 165 × 115 × 49 mm |
| Weight | 1.03 kg |
| Baseline | 125 mm |
| Working range | 380–1000 mm |
| Near FOV | 300 × 250 mm @ 380 mm |
| Far FOV | 650 × 640 mm @ 1000 mm |
| Color camera field of view | H: 56.8° / V: 44.7° |
| Point spacing (point cloud) | 0.33 mm @ 500 mm |
| Exposure mode | Depth: Global shutter · Color: Rolling shutter |
| Accuracy — Z / X-Y | < %0.1 / < %0.5 |
| Resolution — Depth | 1280 × 1024 piksel |
| Resolution — Color camera | 3000 × 2280 piksel |
| Scan time (typical) | 0.7–1.1 sn |
| RGB-D alignment | Yes |
| Data output | Depth, point cloud (wrl/obj/pcd/ply), color camera image |
| API | C++, C#, Python, Halcon |
| Operating system | Windows 10/11, Ubuntu 16.04/18.04/20.04 |
| Hardware interface | PoE IEEE 802.3at · Ethernet M12 X-CODE, GigE, IEEE1588 |
| Operating / Storage temperature | 0–40 °C / −20–70 °C |
| Relative humidity | %20–80 RH |
| Protection class | IP65 |
| Power input / consumption | PoE / 16 W |
All models use a 447 nm blue laser light source and generate up to 1.3 million points per second. The Mini Pro-700 is extremely compact for close-range scans; the Mini Pro C-700 and C-1000 add a color camera and differ by scanning volume.
SCAPE Pro Industrial 3D Scanners
Designed for fixed (overhead) mounting above the scene, the Pro series is offered in two size options. Its binocular scanning architecture makes it stand out in tasks such as bin-picking that require a multi-angle viewing advantage. Because the fixed design doesn't require the robot to wait during data capture, it delivers a shorter cycle time compared to wrist-mounted scanners — in some applications, two bins can be scanned side by side. The color camera strengthens object differentiation, enables surface inspection, and adds texture mapping alongside the geometric data.
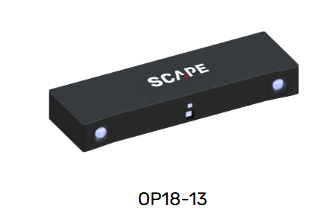
SCAPE Pro C-L
| Dimensions (W×D×H) | 480 × 148 × 65 mm |
| Weight | 3.7 kg |
| Baseline | 400 mm |
| Working range | 1326–2800 mm |
| Extended range | 2800–4000 mm |
| Near FOV | 1100 × 900 mm @ 1326 mm |
| Far FOV | 2100 × 1800 mm @ 2800 mm |
| Color camera field of view | H: 65.6° / V: 51.6° |
| Exposure mode | Grayscale: Global shutter · Color: Rolling shutter |
| Accuracy — Z / X-Y | < %0.1 / < %0.5 |
| Resolution — Depth | 1624 × 1240 piksel |
| Resolution — Color camera | 3264 × 2464 piksel |
| Frame rate (depth) | Up to 1.5 fps |
| RGB-D alignment | Yes |
| API | C++, C#, Python, Halcon |
| Operating system | Windows 10/11, Ubuntu 16.04/18.04/20.04 |
| Hardware interface | Hirose 8pin (12–30 VDC) · Ethernet M12 X-CODE, GigE, IEEE1588 |
| Indicator | 3 LED |
| Operating / Storage temperature | 0–40 °C / −20–70 °C |
| Relative humidity | %20–80 RH |
| Protection class | IP65 |
| Power input / consumption | 24 VDC ≥2A / 48 W |
| Certification | CE / FCC · Laser Safety Class 3R |
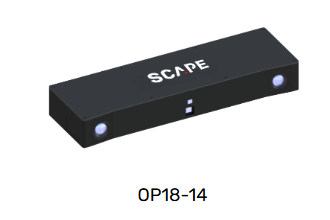
SCAPE Pro C-XL
| Dimensions (W×D×H) | 480 × 148 × 68 mm |
| Weight | 3.74 kg |
| Baseline | 400 mm |
| Working range | 1100–3500 mm |
| Extended range | 3500–4900 mm |
| Near FOV | 1050 × 1000 mm @ 1100 mm |
| Far FOV | 3200 × 3100 mm @ 3500 mm |
| Color camera field of view | H: 75° / V: 60° |
| Exposure mode | Grayscale: Global shutter · Color: Rolling shutter |
| Accuracy — Z / X-Y | < %0.1 / < %0.5 |
| Resolution — Depth | 1624 × 1240 piksel |
| Resolution — Color camera | 3248 × 2480 piksel |
| Frame rate (depth) | Up to 1.5 fps |
| RGB-D alignment | Yes |
| API | C++, C#, Python, Halcon |
| Operating system | Windows 10/11, Ubuntu 16.04/18.04/20.04 |
| Hardware interface | Hirose 8pin (12–30 VDC) · Ethernet M12 X-CODE, GigE, IEEE1588 |
| Indicator | 3 LED |
| Operating / Storage temperature | 0–40 °C / −20–70 °C |
| Relative humidity | %20–80 RH |
| Protection class | IP65 |
| Power input / consumption | 24 VDC ≥2A / 48 W |
| Certification | CE / FCC · Laser Safety Class 3R |
Suited to bin-picking, object detection (pose estimation), de-palletizing/palletizing and wide-area applications. Able to scan from small to very large areas, the Pro C-XL model is especially preferred for large-surface applications.
SCAPE Ultra Industrial 3D Scanners
Designed for fixed mounting, the monocular Ultra series delivers high-accuracy, low-noise point cloud data. A built-in shutter mechanism keeps projection light from spilling outside the scene, preserving data quality. Because its fixed design means the robot doesn't need to wait during data capture, cycle time can be reduced to as little as 1 second.
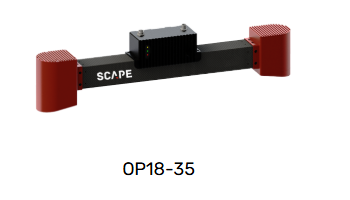
SCAPE Ultra-L
| Dimensions (W×D×H) | 647 × 165 × 78 mm |
| Weight | 2.49 kg |
| Baseline | 550 mm |
| Working range | 1057–2070 mm |
| Near FOV | 800 × 700 mm @ 1057 mm |
| Far FOV | 1700 × 1400 mm @ 2070 mm |
| Exposure mode (Depth) | Global shutter |
| Accuracy — Z / X-Y | < %0.1 / < %0.5 |
| Resolution (Z / depth) | 1624 × 1240 piksel |
| Scan time (typical) | 0.9–1.5 sn |
| Data output | Depth, point cloud — wrl, obj, pcd, ply |
| API | C++, C#, Python, Halcon |
| Operating system | Windows 10/11, Ubuntu 16.04/18.04/20.04 |
| Hardware interface | Hirose 8pin (12–30 VDC) · Ethernet M12 X-CODE, GigE, IEEE1588 |
| Operating / Storage temperature | 0–40 °C / −20–70 °C |
| Relative humidity | %20–80 RH |
| Protection class | IP65 |
| Power input / consumption | 24 VDC ≥2A / 35 W |
| Certification | CE / FCC · Laser Safety Class 3R |
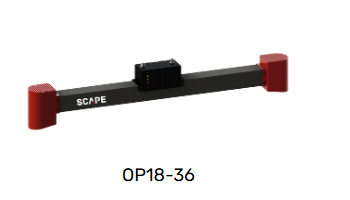
SCAPE Ultra-XL
| Dimensions (W×D×H) | 966 × 165 × 80 mm |
| Weight | 2.95 kg |
| Baseline | 860 mm |
| Working range | 1521–3800 mm |
| Near FOV | 1300 × 1000 mm @ 1521 mm |
| Far FOV | 2600 × 2500 mm @ 3800 mm |
| Exposure mode (Depth) | Global shutter |
| Accuracy — Z / X-Y | < %0.1 / < %0.5 |
| Resolution (Z / depth) | 2048 × 1536 piksel |
| Scan time (typical) | 0.9–1.5 sn |
| Data output | Depth, point cloud — wrl, obj, pcd, ply |
| API | C++, C#, Python, Halcon |
| Operating system | Windows 10/11, Ubuntu 16.04/18.04/20.04 |
| Hardware interface | Hirose 8pin (12–30 VDC) · Ethernet M12 X-CODE, GigE, IEEE1588 |
| Operating / Storage temperature | 0–40 °C / −20–70 °C |
| Relative humidity | %20–80 RH |
| Protection class | IP65 |
| Power input / consumption | 24 VDC ≥2A / 35 W |
| Certification | CE / FCC · Laser Safety Class 3R |
Suited to a broad range of applications including high-precision bin-picking, object detection, depth-data extraction, industrial inspection and machine guidance. Offers scanning from mid-sized to very large areas.